Problem
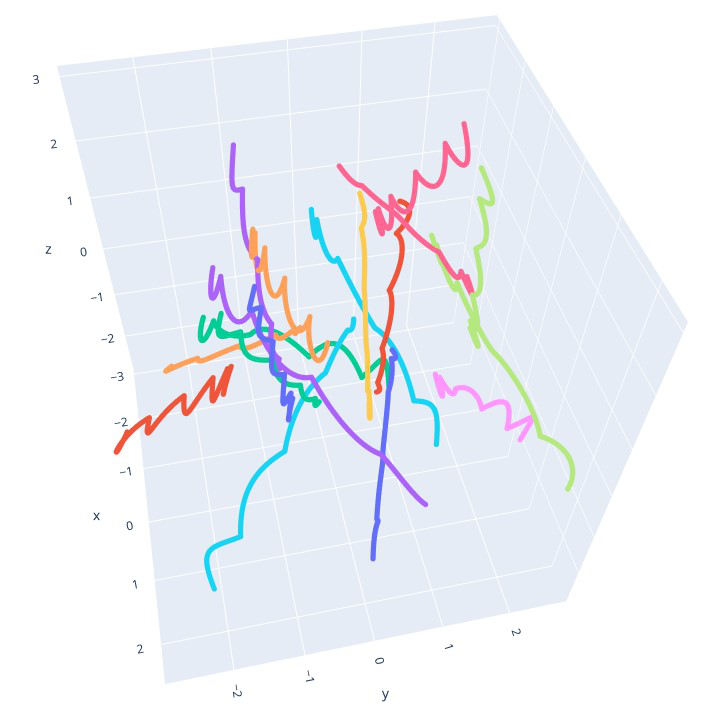
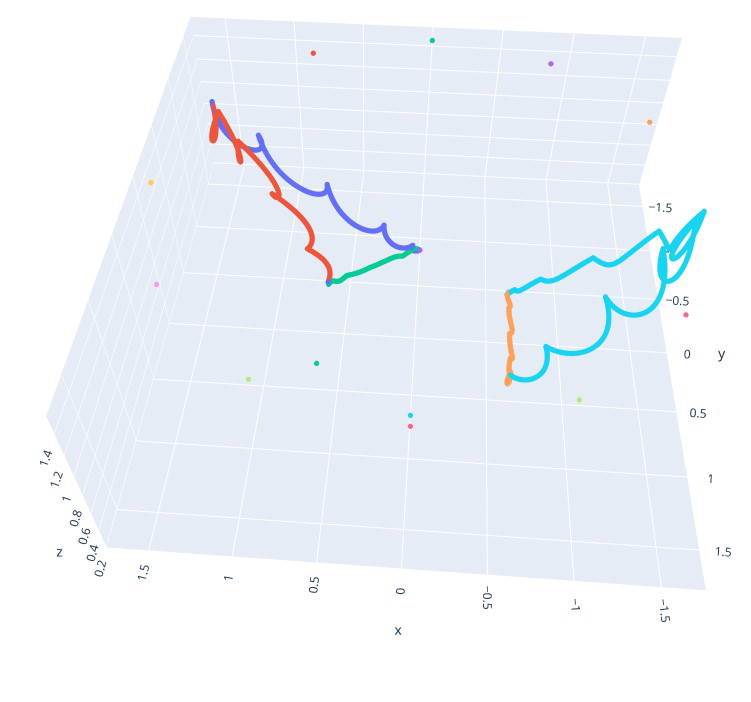
Launch-vehicle constraints limit the aperture of monolithic space telescopes. MACRO asks how multiple spacecraft could autonomously assemble a larger parabolic structure after deployment in an elliptic orbit.
Selected research
Multi-agent space assembly
Coordinating spacecraft to assemble structures too large to launch in one piece, through task allocation, motion planning, and attitude control.
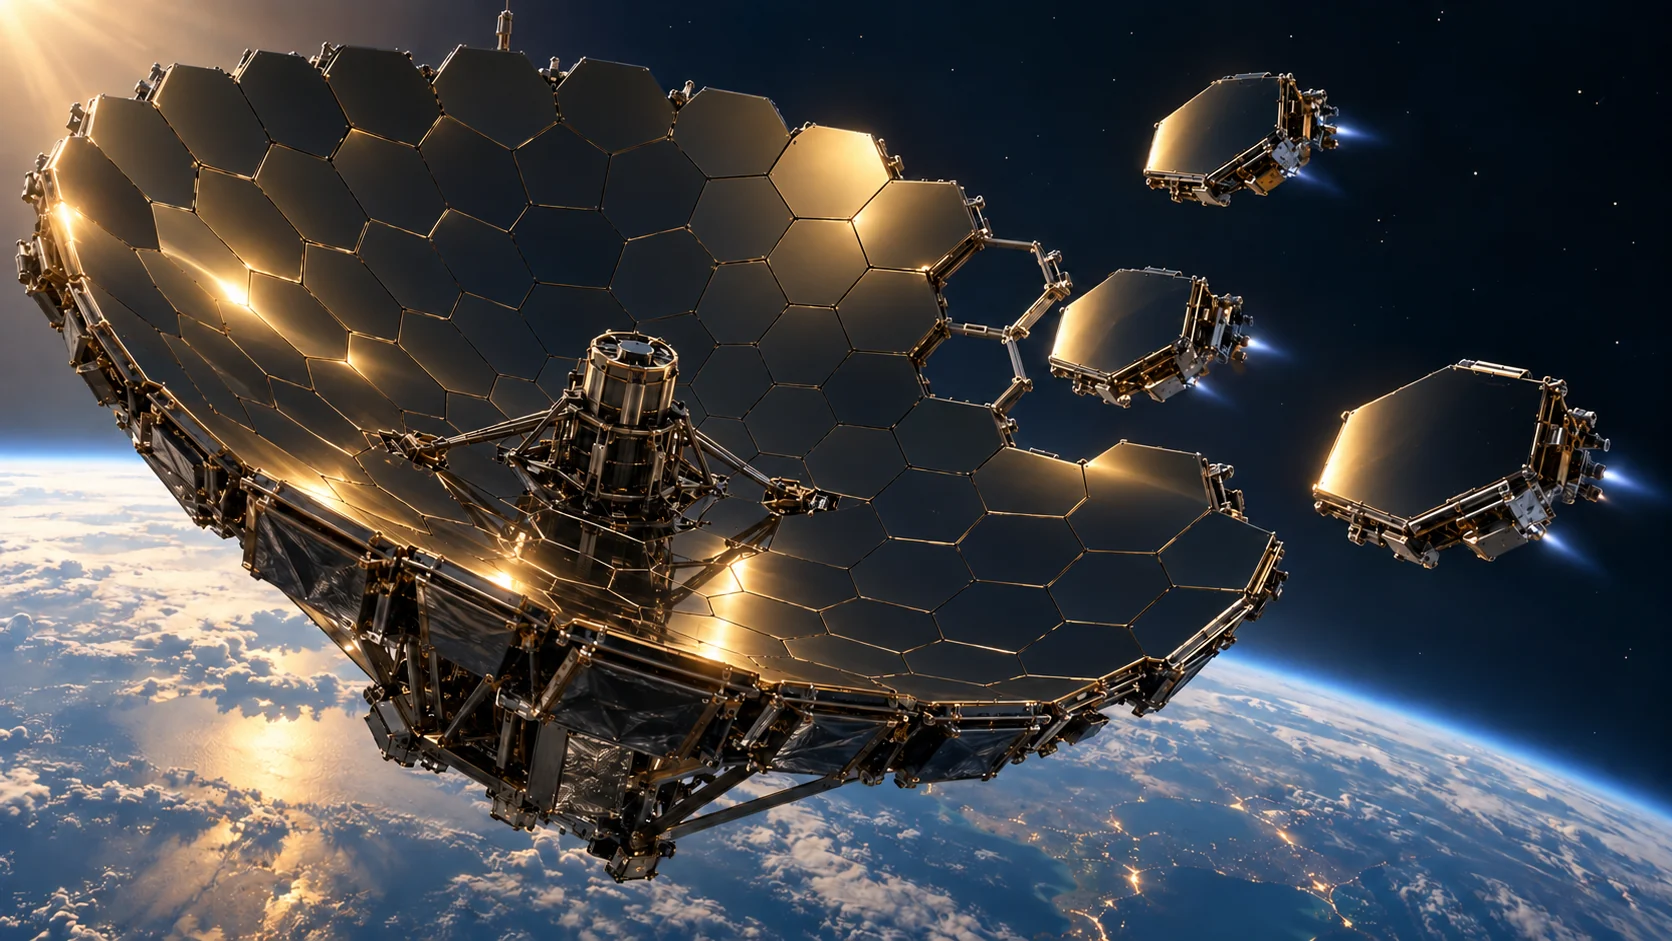
Launch-vehicle constraints limit the aperture of monolithic space telescopes. MACRO asks how multiple spacecraft could autonomously assemble a larger parabolic structure after deployment in an elliptic orbit.
I developed this framework in my undergraduate thesis at IIT Bombay, supervised by Dwaipayan Mukherjee, bringing together spacecraft allocation, formation maneuvers, and attitude coordination.
The framework decomposes the assembly problem into allocation, collision-aware formation maneuvers, local attitude synchronization, and convergence to prescribed positions and orientations around a central spacecraft.
The public repository packages the simulation methods accompanying the undergraduate thesis and paper.
The work was published at the 2021 Indian Control Conference and released with its simulation code and undergraduate thesis.
Simulation studies examine the coordinated assembly formulation in an elliptic orbit.
Citation
Peer-reviewed conference paper · Indian Control Conference, 2021